Bachelor of Engineering (S.T.), Engineering Physics
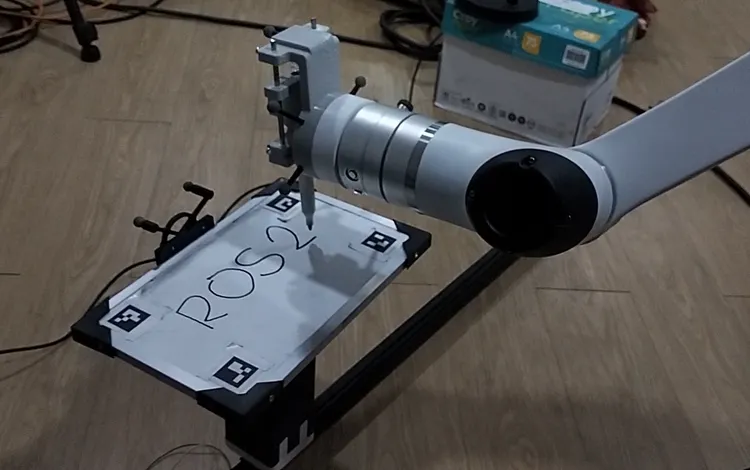
Trajectory Tracking Control for a 6-DOF Robot Arm using an Optical Tracking-Based 3D Task Space Estimator
Co-author, "Tracking and Sway Control of Gantry Crane Using Zero-Vibration-Derivative Input Shaping and Partial Feedback Linearization," presented at ASCC 2026
Research and Development Engineer at Nakayama – ITB deLabo
From March 2025 to Present at Bandung, IndonesiaArchitected a battery monitoring system integrating BMS with Raspberry Pi/Jetson Nano and PLC via Modbus TCP/RTU, MQTT, and FTP for reliable industrial data transmission. Built a conveyor belt load-rate measurement system using an OAK-D Pro depth camera for real-time volumetric scanning. Built a real-time dashboard for data visualization and automated logging, improving system observability for the research team.
Teaching Assistant, Discrete Control Systems at Bandung Institute of Technology
From September 2025 to January 2026 at Bandung, IndonesiaDesigned laboratory modules on DC motor control dynamics and mentored students on PID controller implementation and discrete system analysis. Programmed ladder logic for industrial automation scenarios using Mitsubishi PLC.
Robotics Engineer Intern at Formulatrix
From July 2025 to September 2025 at Bandung, IndonesiaEngineered a collision-detection algorithm with a gentle-release mechanism for a SCARA robot gripper, reducing damage risk to delicate microplates during handling. Developed an input-shaping control strategy to suppress residual liquid-slosh vibration in moving containers, validated via smoothed particle hydrodynamics (SPH) simulation in Python. Implemented forward and inverse kinematics solvers to optimize SCARA trajectory execution and motion precision.
Robotics Software Engineer at Unit Robotika ITB – Dagozilla Soccer Robot Team
From August 2023 to August 2025 at Bandung, IndonesiaDeployed a real-time object and line detection system (YOLO) integrated with the robot's ROS navigation stack. Engineered strategic motion-planning algorithms for autonomous setplay scenarios and optimized the C++/Python codebase for low-latency communication.
Laboratory Assistant Coordinator at Bandung Institute of Technology
From February 2025 to July 2025 at Bandung, IndonesiaLed a team of 20 assistants delivering Engineering Physics Lab II (embedded systems) experiments for 80+ students; refined curriculum and lab modules on microcontroller architecture and interfacing.
IoT Engineer Intern at Kedaireka.id
From June 2024 to December 2024 at Bandung, IndonesiaEngineered a dual-axis solar tracker system with SolidWorks-designed schematics and control panel assemblies; integrated sensor networks with control algorithms for real-time monitoring.
Team Leader, AUV Project at Skullers BORO, ITB
From November 2024 to March 2026 at Bandung, IndonesiaLed a 12-member cross-functional team (mechanical, electrical, software) to design and build an autonomous underwater vehicle, successfully qualifying for the Singapore AUV Challenge (SAUVC) 2025. Concurrently served as Initiatives Manager (HMFT ITB, Jun 2024 – Mar 2025), drafting proposals and frameworks that secured approval and funding for reviving the BORO robotics community.
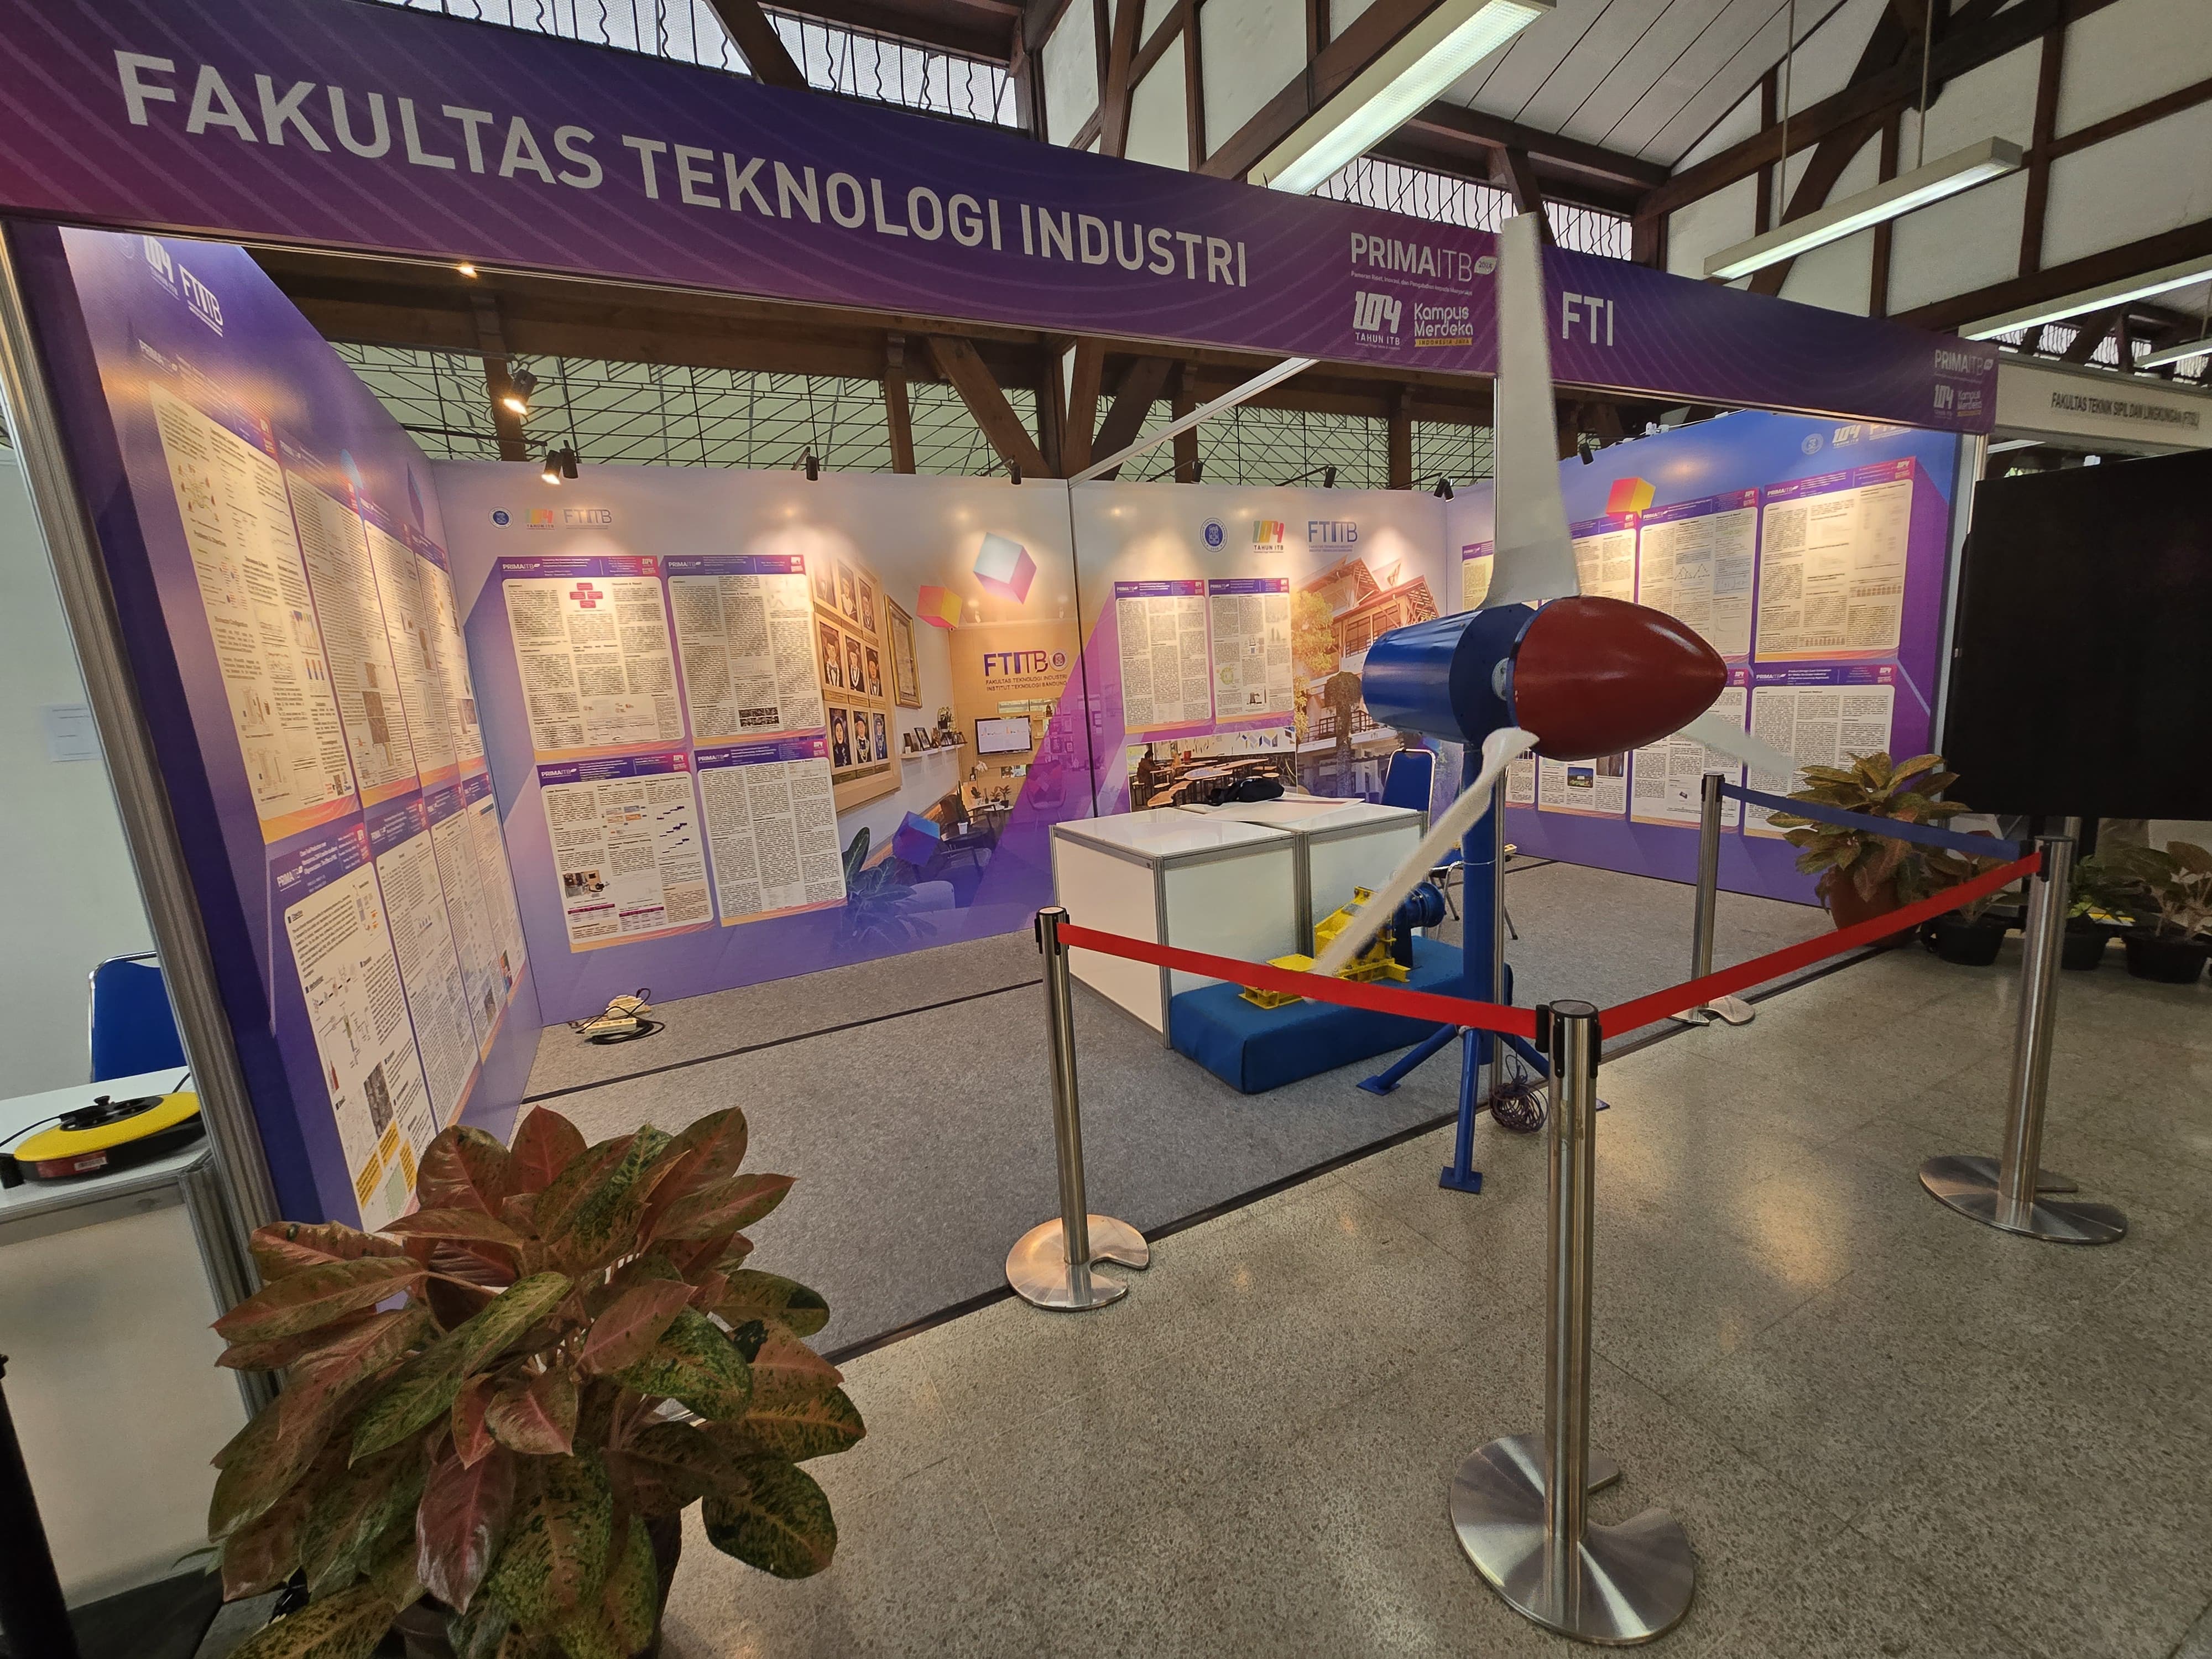
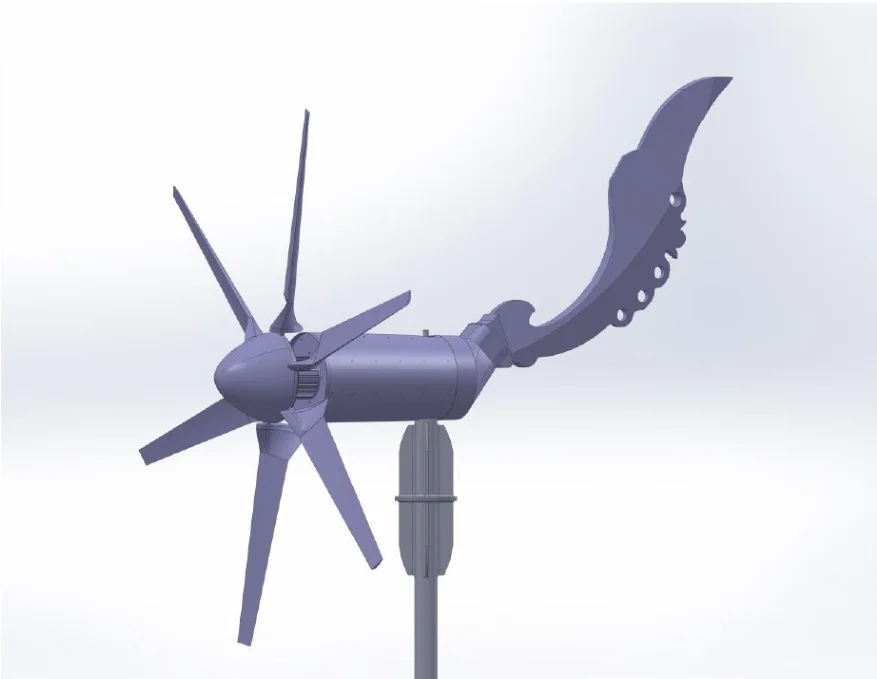
A wind turbine whose tail vane is shaped like the kujang, a traditional West Javan blade, giving the turbine a distinctive look rooted in Indonesian culture.
An educational demonstration kit (ALPEDU PLTB) for a low-speed wind power plant.